Work / Perception, AI Hardware
LiDAR perception
Detecting and tracking people directly from laser scans
Cameras struggle with lighting and privacy, so this project built the perception layer directly on LiDAR. It is a complete, end-to-end AI system covering data collection and labelling, model training, multi-frame tracking and deployment on the target hardware, tuned until it performed reliably in real operation.
Challenge
A 2D laser scan is sparse and ambiguous: a person, a chair leg and a wall corner can all look alike in a single frame.
Approach
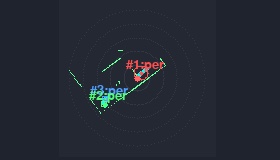
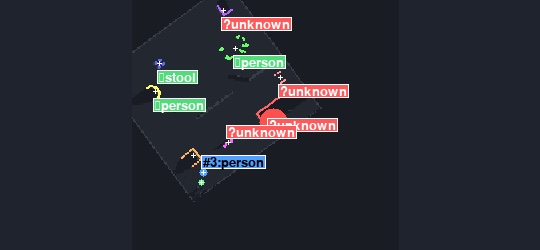
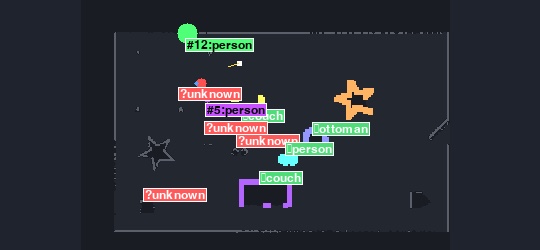
A U-Net-based semantic segmentation model classifies objects in 2D LiDAR data. Zero-shot learning lets the system recognise new object types without retraining from scratch, and a dynamic tracking module follows people and moving objects across frames while keeping their identities. The tracker was first developed and validated in simulation against moving and static targets.
Result
Deployed on the target hardware and running in real operation.
In brief
- Complete pipeline: data collection, labelling, training, tracking and deployment
- U-Net semantic segmentation on LiDAR data
- Zero-shot recognition of new objects
- Real-time human and dynamic-object tracking
From the project